MIST
Robotics / Mechanical — Apr – Jun 2026
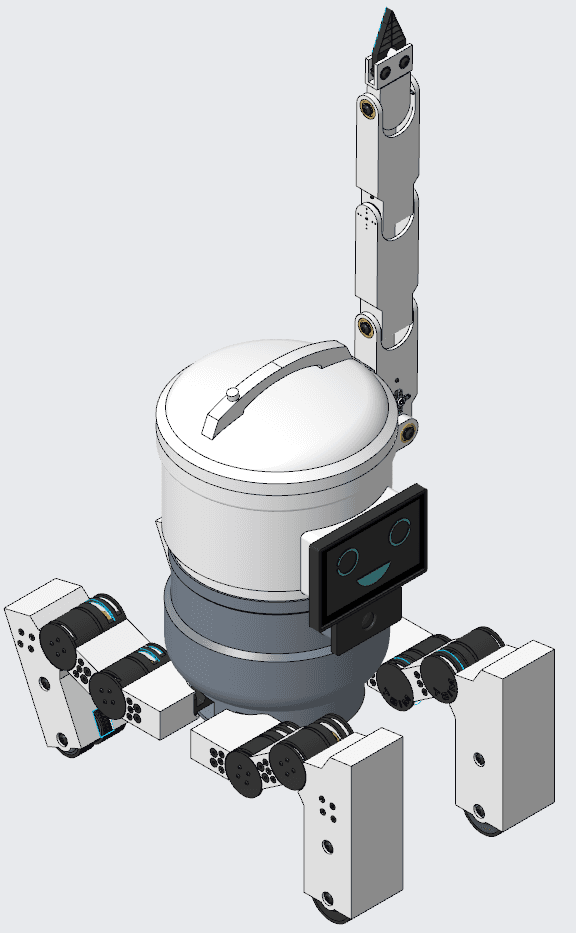
A rice cooker that learned to walk. A quadruped, wheel-legged companion robot, designed from the joints up.
Mechanical & CAD Lead, Hack Club Fallout
What I did
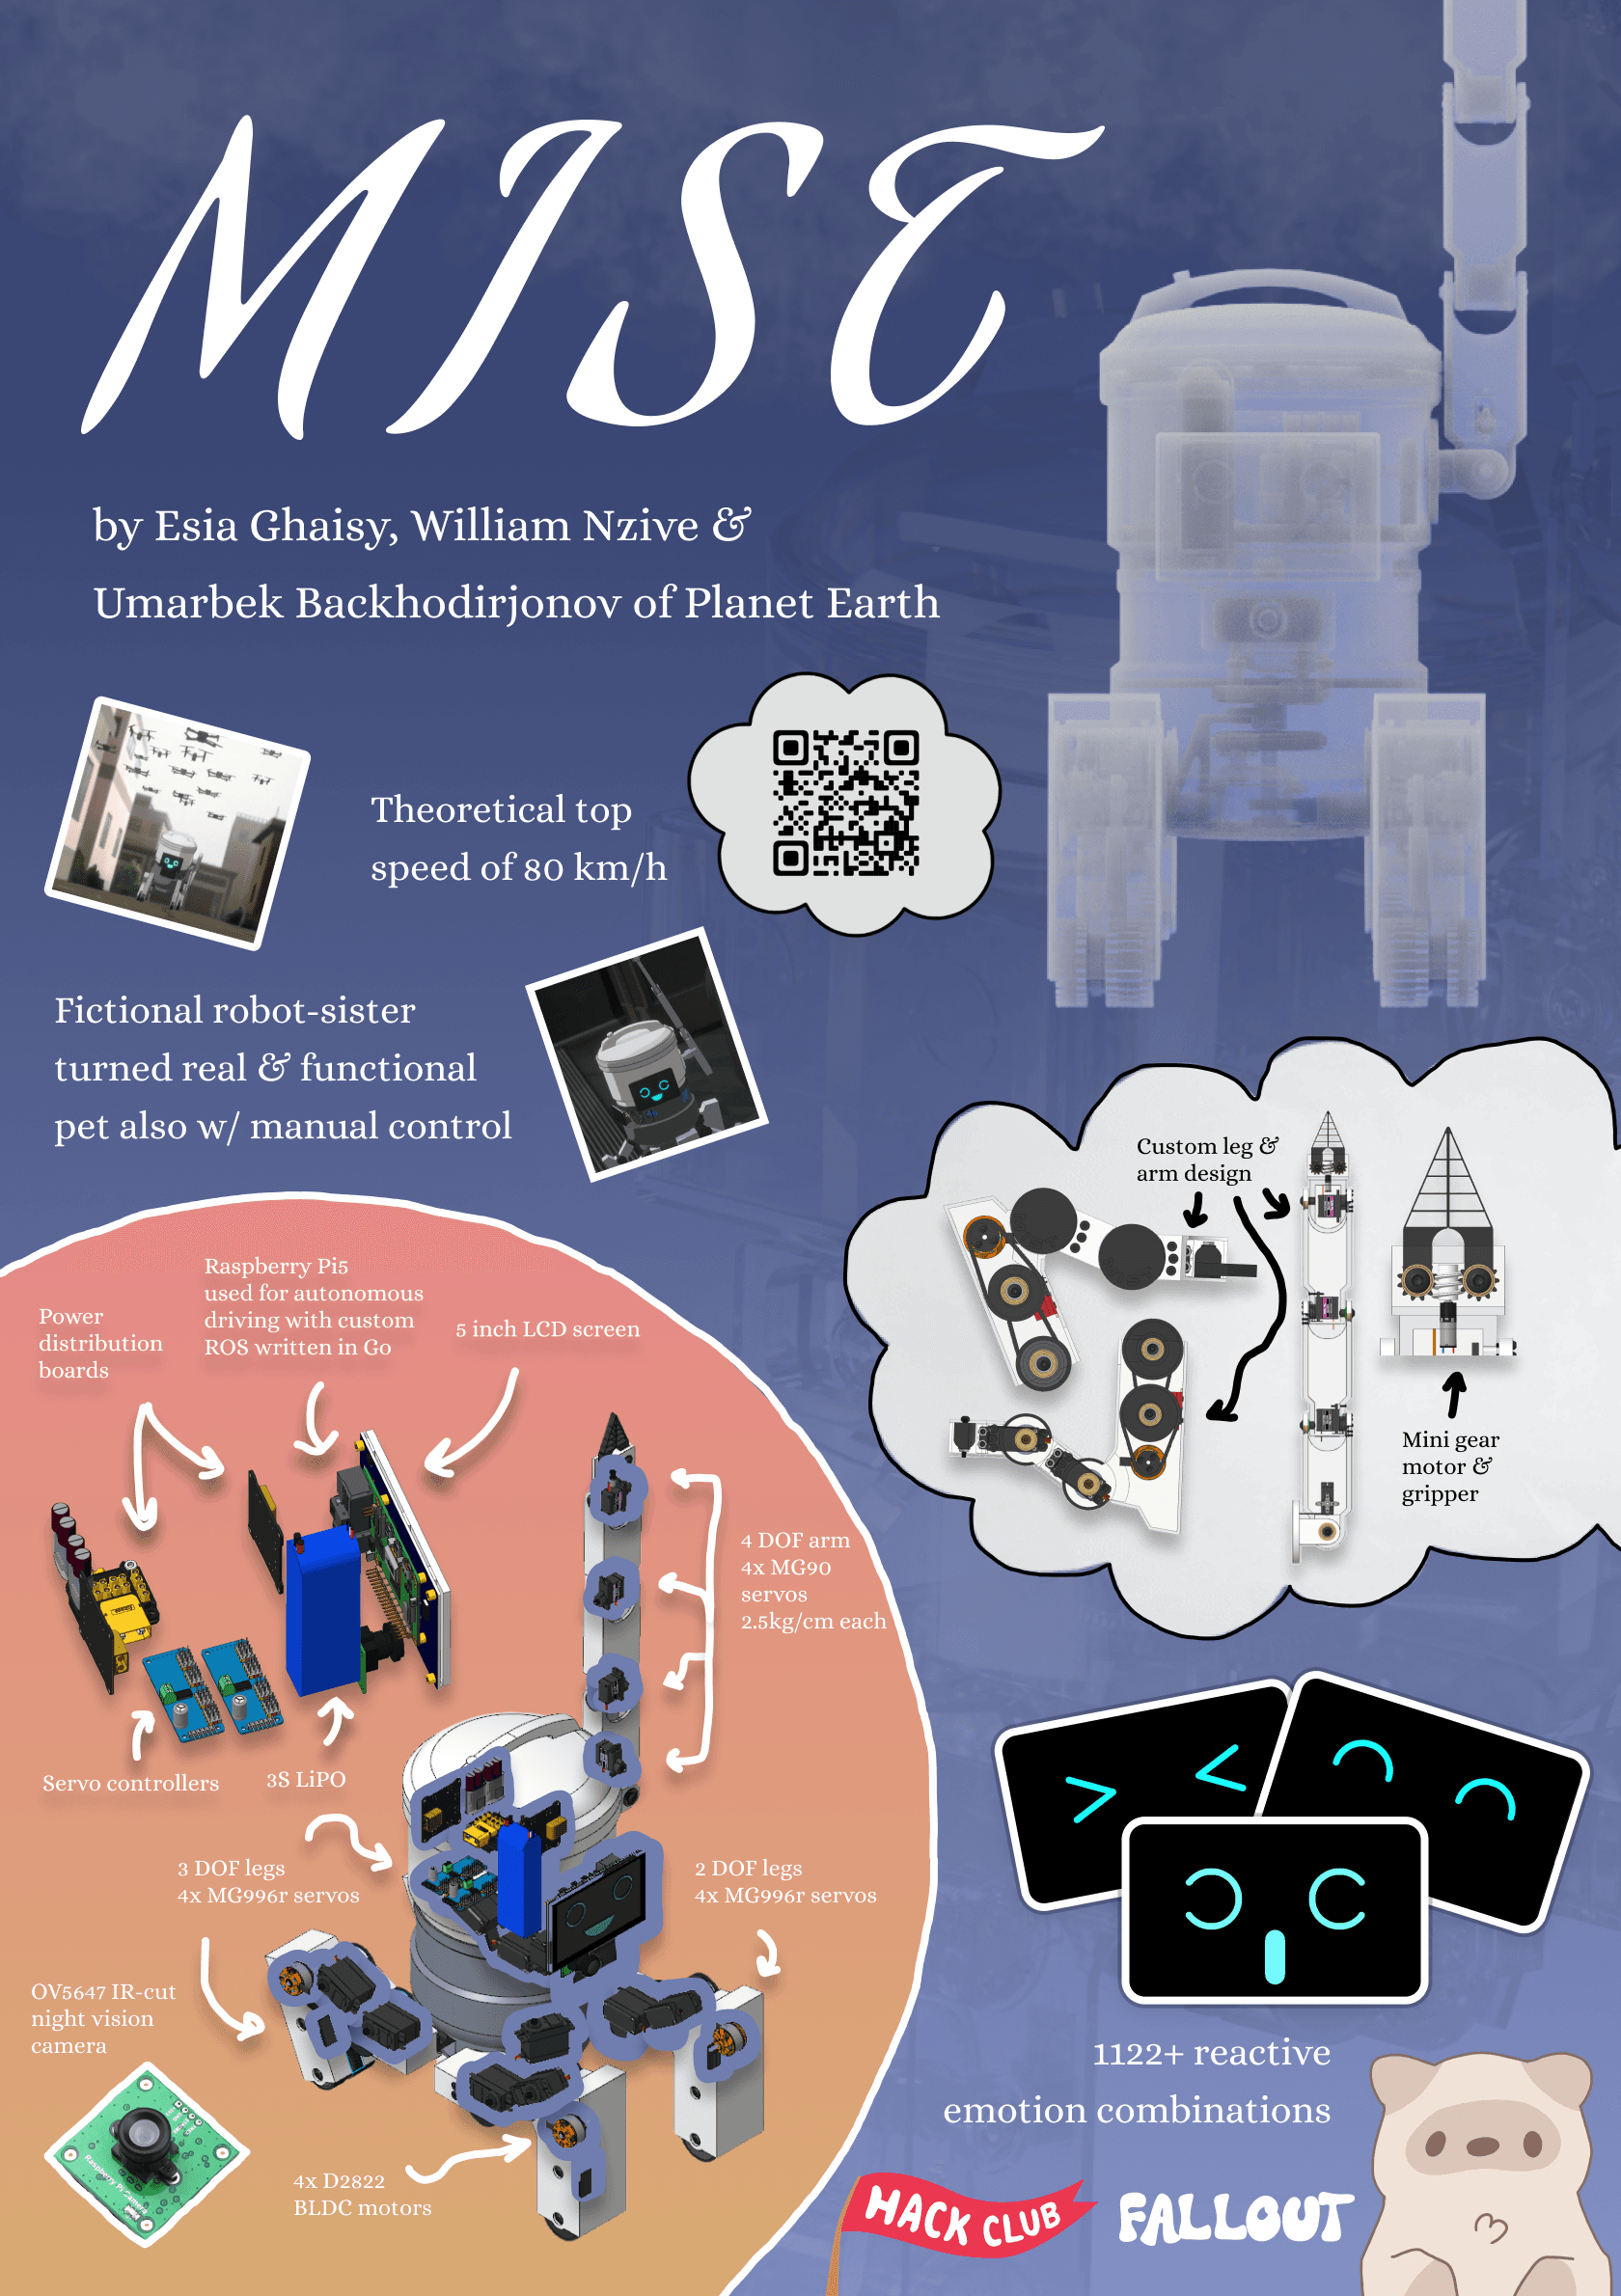
- Designed a quadruped, wheel-legged robot in PTC Creo: four 2-joint legs with servo-driven hips and knees, and belt-driven wheels powered by 4 brushless motors.
- Iterated a modular coaxial bearing joint through 3 versions, moving each servo inside its leg segment to remove part interference and reuse one joint design across the robot.
- Sized joint servos from a torque budget (7 kg robot, 18 cm legs, about 11.8 kg·cm per joint) and geared the wheel drive from motor power and traction estimates.
- Selected the electronics with a teammate: Raspberry Pi 5, 2× PCA9685 servo drivers, an MPU-6050 IMU over I²C, a 3S 11.1 V LiPo with 5 V UBECs and power distribution boards; cut the BOM by about $200.
- Published an open replication guide: Creo/STEP assembly, BOM, wiring schematics and build notes.
Stack
- PTC Creo
- Raspberry Pi 5
- PCA9685
- MPU-6050
- Go
Collaboration
Team build for Hack Club Fallout. The robot software, a custom ROS-style stack in Go, was written by a teammate.